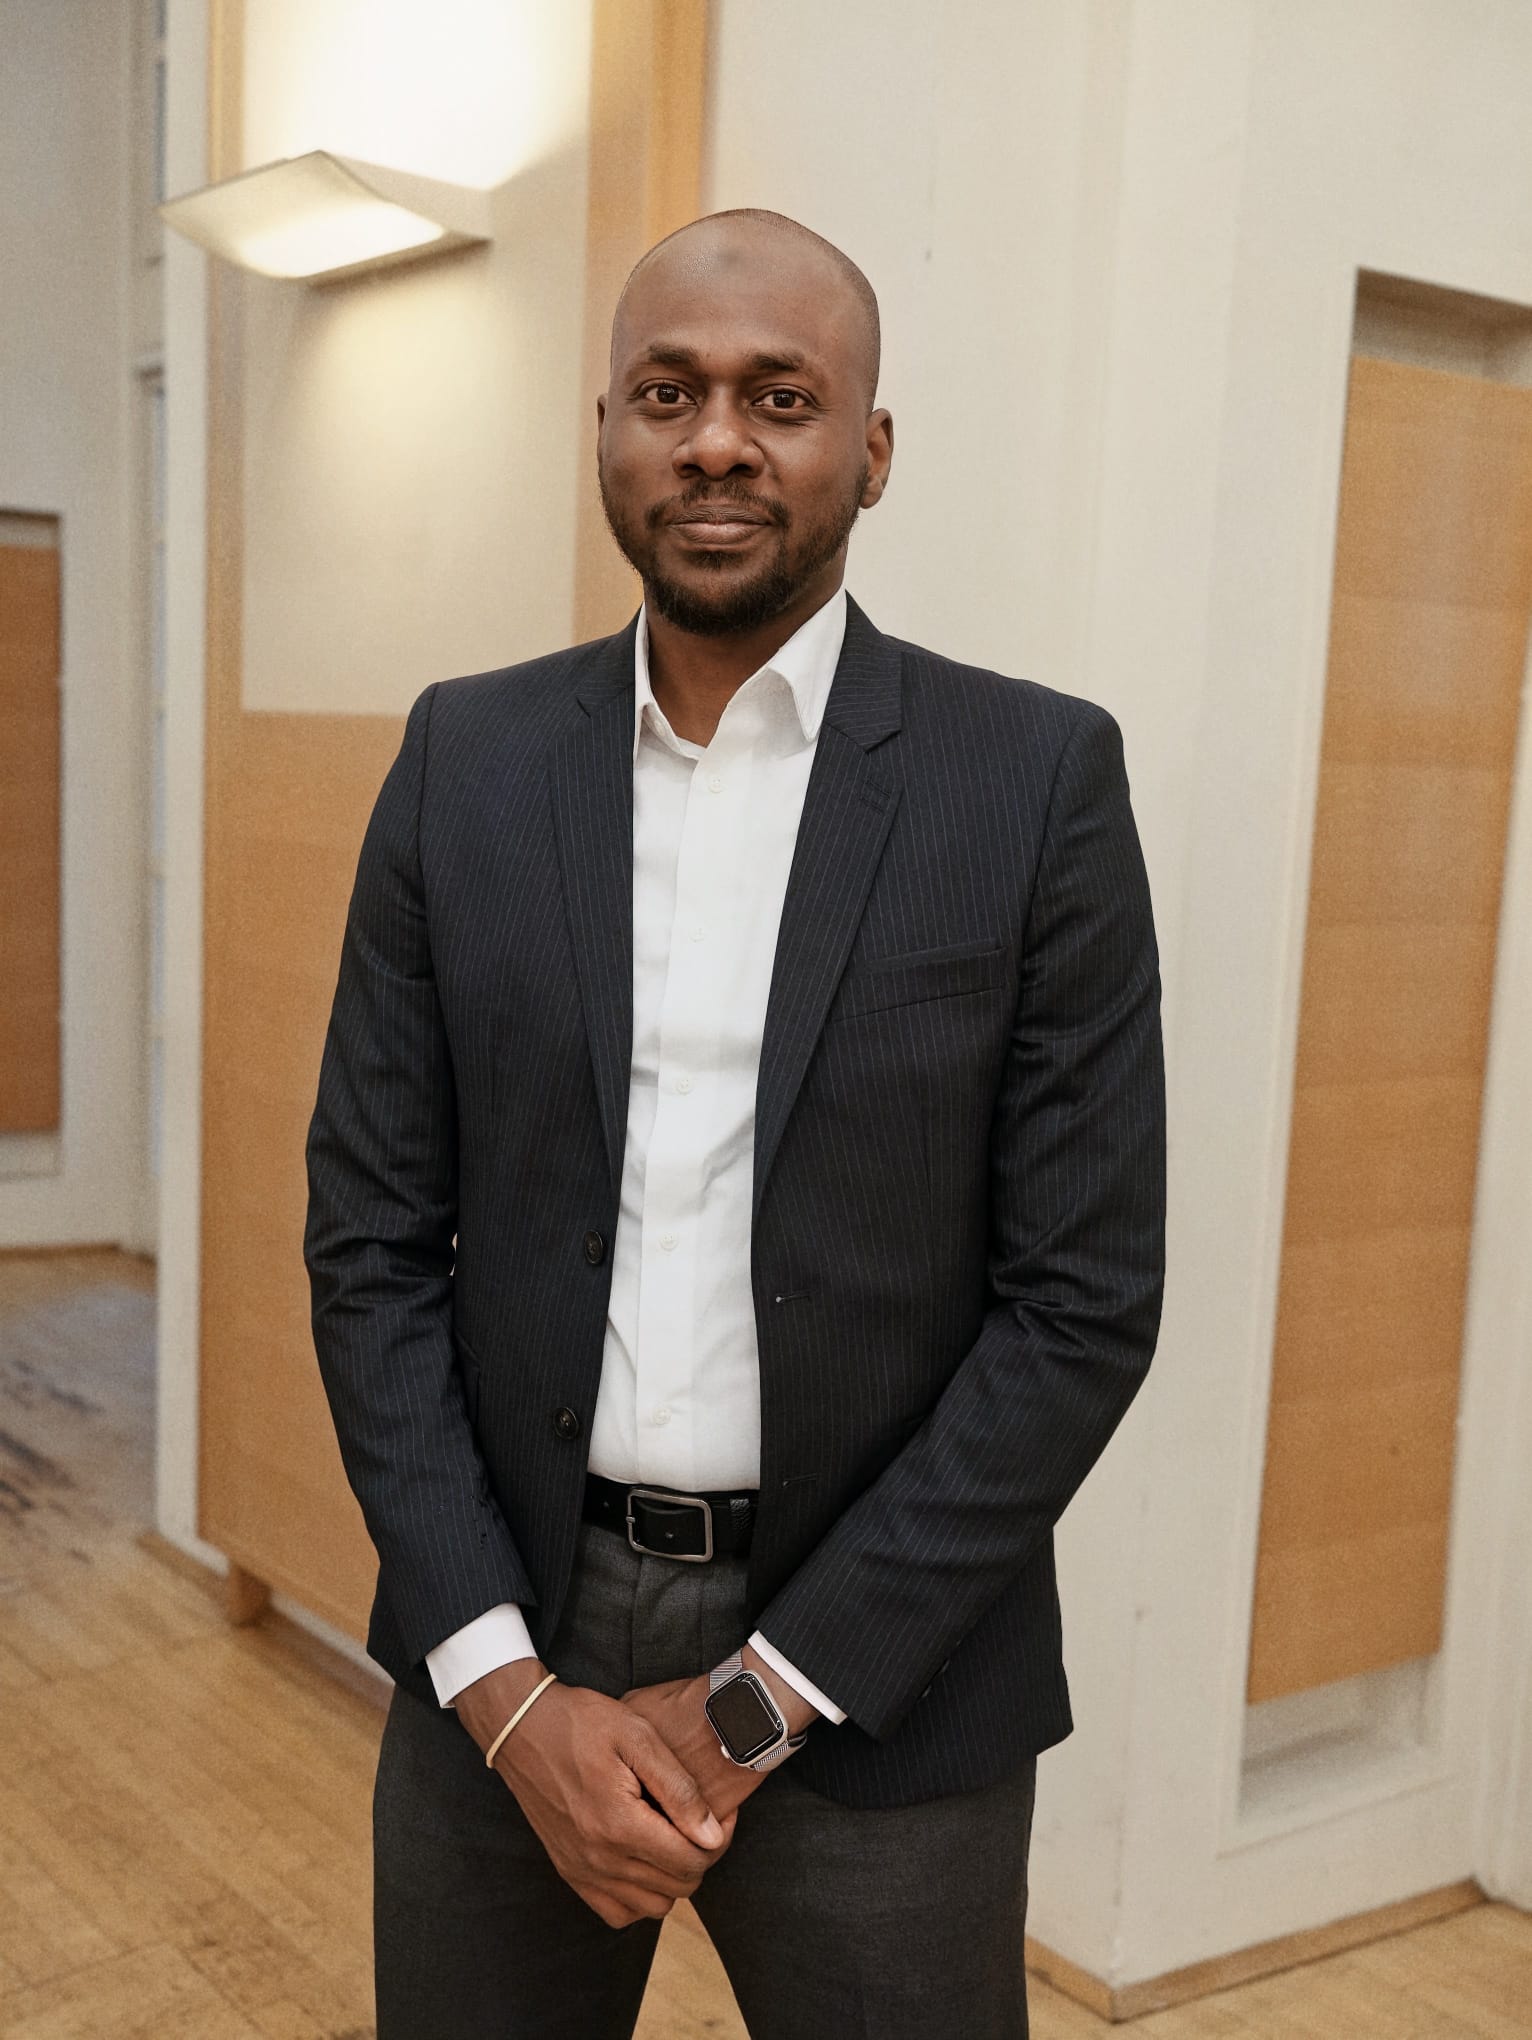
Mazin Abdallah
Session Speaker
Mazin Abdallah is a PhD Researcher in Cybernetics at the Slovak University of Technology in Bratislava (STU), specializing in advanced machine vision systems, event-based cameras, and low-power perception modules for autonomous and intelligent robotic systems. He earned his M.Sc. in Instrumentation Science from Savitribai Phule Pune University, India, in 2021, where he was awarded the prestigious Dr. Shankarrao Ranchoddas Govarikar Gold Medal for ranking first in the university with an 'O' grade. He also holds a B.Sc. in Physics from Sudan University of Science and Technology, Sudan, and is currently pursuing doctoral research in cybernetics at STU Bratislava. Prior to his academic career, he accumulated over eight years of hands-on industrial experience as a Calibration Engineer at the Sudanese Standards and Metrology Organization, where he ensured full laboratory compliance with ISO/IEC 17025, managed institution-wide instrumentation and quality protocols, and coordinated calibration schedules across all branches. He also served as a Research Assistant at the Sudanese Nuclear and Radiological Regulatory Authority, where he administered licensing and inspection procedures for industrial facilities, ensuring compliance with national radiological regulations. Beyond his research, he delivers technical tutorials in MATLAB, robotics, intelligent systems, and Plant Simulate software to bachelor's and master's students, and supervises undergraduate final year projects. His research interests include neuromorphic vision systems, event-based sensing, machine vision, intelligent perception, multi-criteria decision frameworks for vision system selection, and the integration of emerging sensing technologies into smart manufacturing systems. His recent scholarly contributions include a seminal survey on neuromorphic vision systems in industrial robotics perception (RAAD 2026, Springer) and a novel multi-criteria decision framework for selecting vision systems in industrial applications (ISMCR 2026, Rio de Janeiro). In addition to his research contributions, he actively serves the scientific community as a reviewer for the RAAD conference (International Conference on Robotics in Alpe-Adria-Danube Region). His work continues to bridge theoretical innovation and practical implementation in modern robotic perception and intelligent systems.
From Pixels to Events: Transforming Industrial Robot Perception with Neuromorphic Vision Abstract The third generation of artificial intelligence, introduced by neuromorphic computing, is revolutionizing the way robots and autonomous systems perceive the world. Unlike traditional frame-based cameras that capture redundant visual data at fixed intervals, neuromorphic vision sensors, inspired by biological retinas, generate sparse, asynchronous streams of events in response to changes in the scene. This paradigm shift offers unprecedented advantages for industrial robotics: microsecond-level latency, orders-of-magnitude reduction in data bandwidth, and robust performance under challenging lighting and high-speed motion conditions.Drawing from a systematic survey of the field, including my own seminal contributions to the RAAD article on neuromorphic vision systems in industrial robotics perception, this presentation will examine how these biologically-inspired sensors are fundamentally reshaping industrial robot perception pipelines. I will cover the fundamental principles of event-based sensing, the design of neuromorphic vision chips that integrate sensing, memory, and processing in real time, and the algorithmic innovations required to unlock their full potential. Case studies will illustrate successful deployments in areas such as high-speed inspection, dynamic obstacle avoidance, and human-robot collaboration. The talk will conclude with a critical assessment of barriers to widespread industrial adoption and a forward-looking vision for how neuromorphic perception can become a cornerstone of intelligent, adaptive manufacturing systems in the Industry 5.0 era. Keywords: Real-Time Perception, Neuromorphic Vision, Event-Based Cameras, Industrial Automation, Low-Latency Systems